
Coordinate systems
Create user-defined coordinate systems for use in individual program actions. They are useful for applications such as palletising on an inclined surface.
Coordinate systems
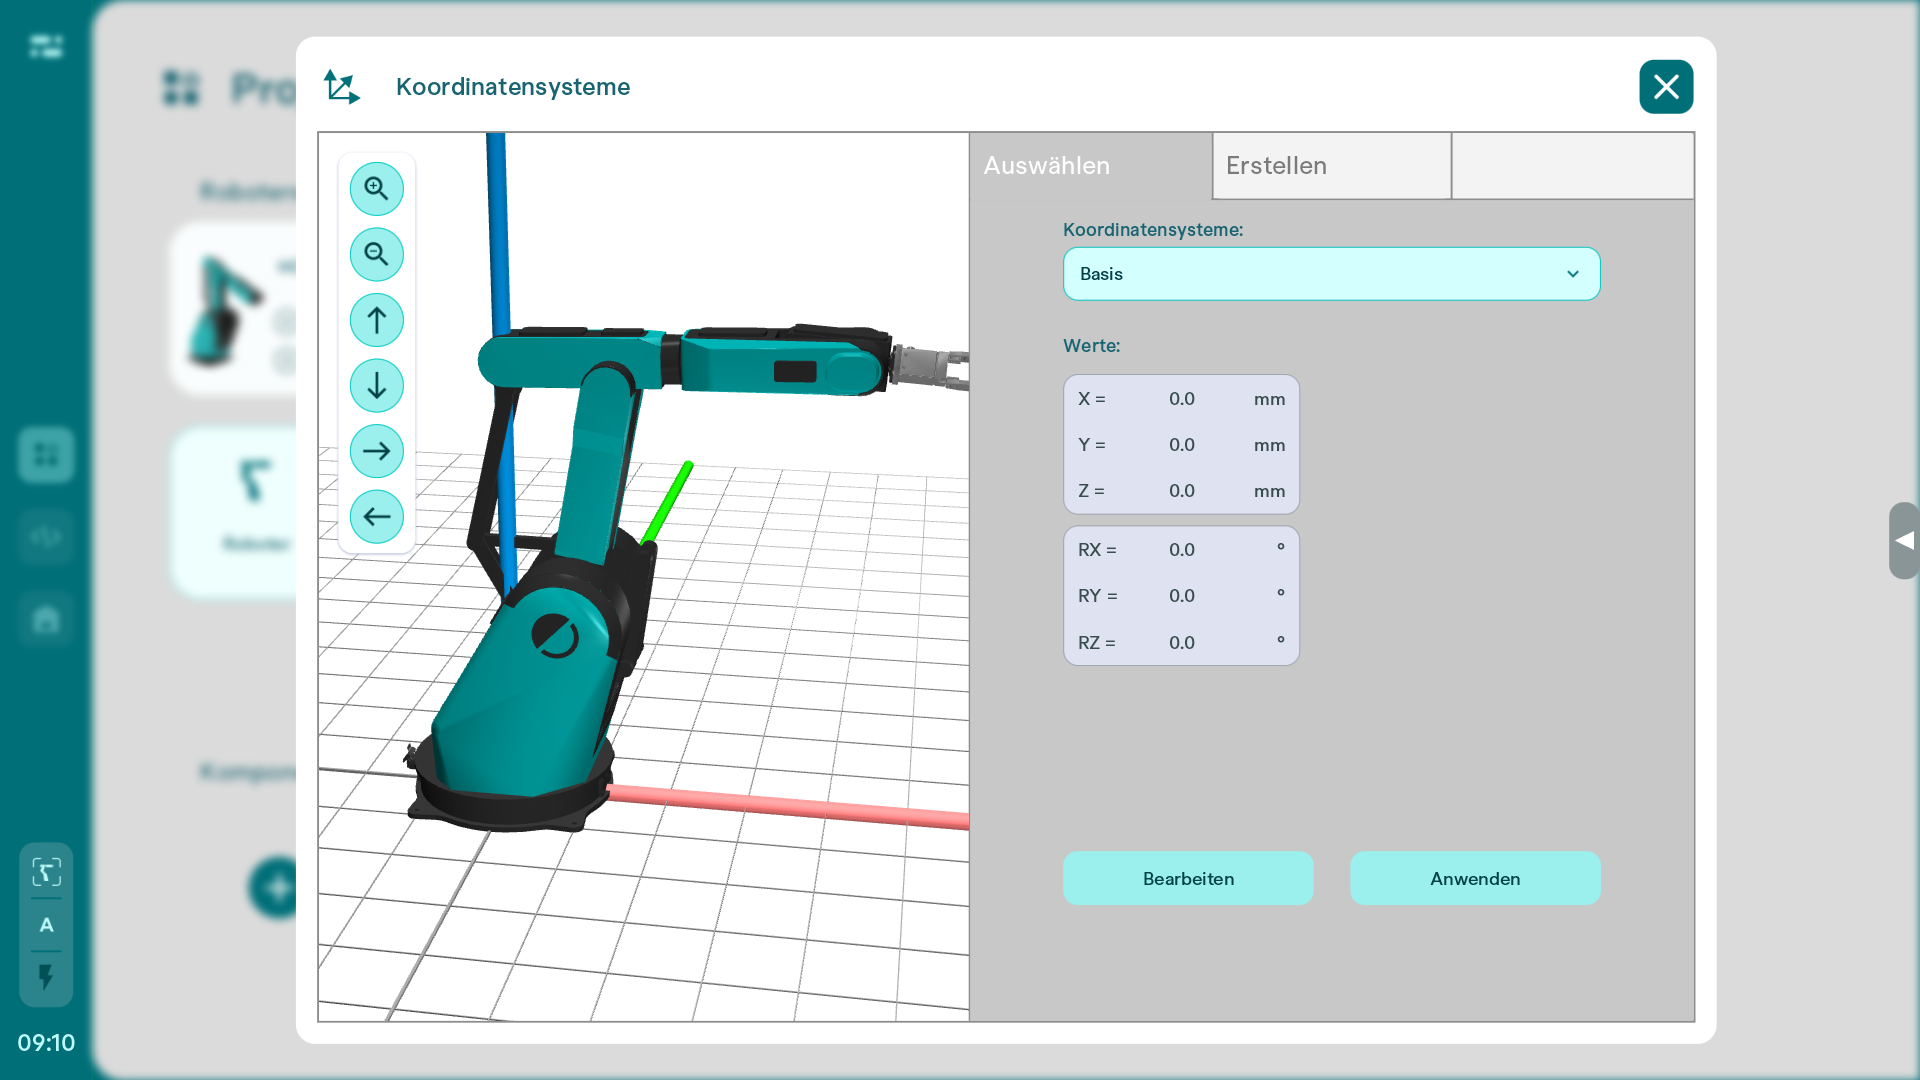
Create a coordinate system by defining its offset and orientation. Enter the values directly or teach them by moving the robot to points. The coordinate system can be adjusted after it has been created.