
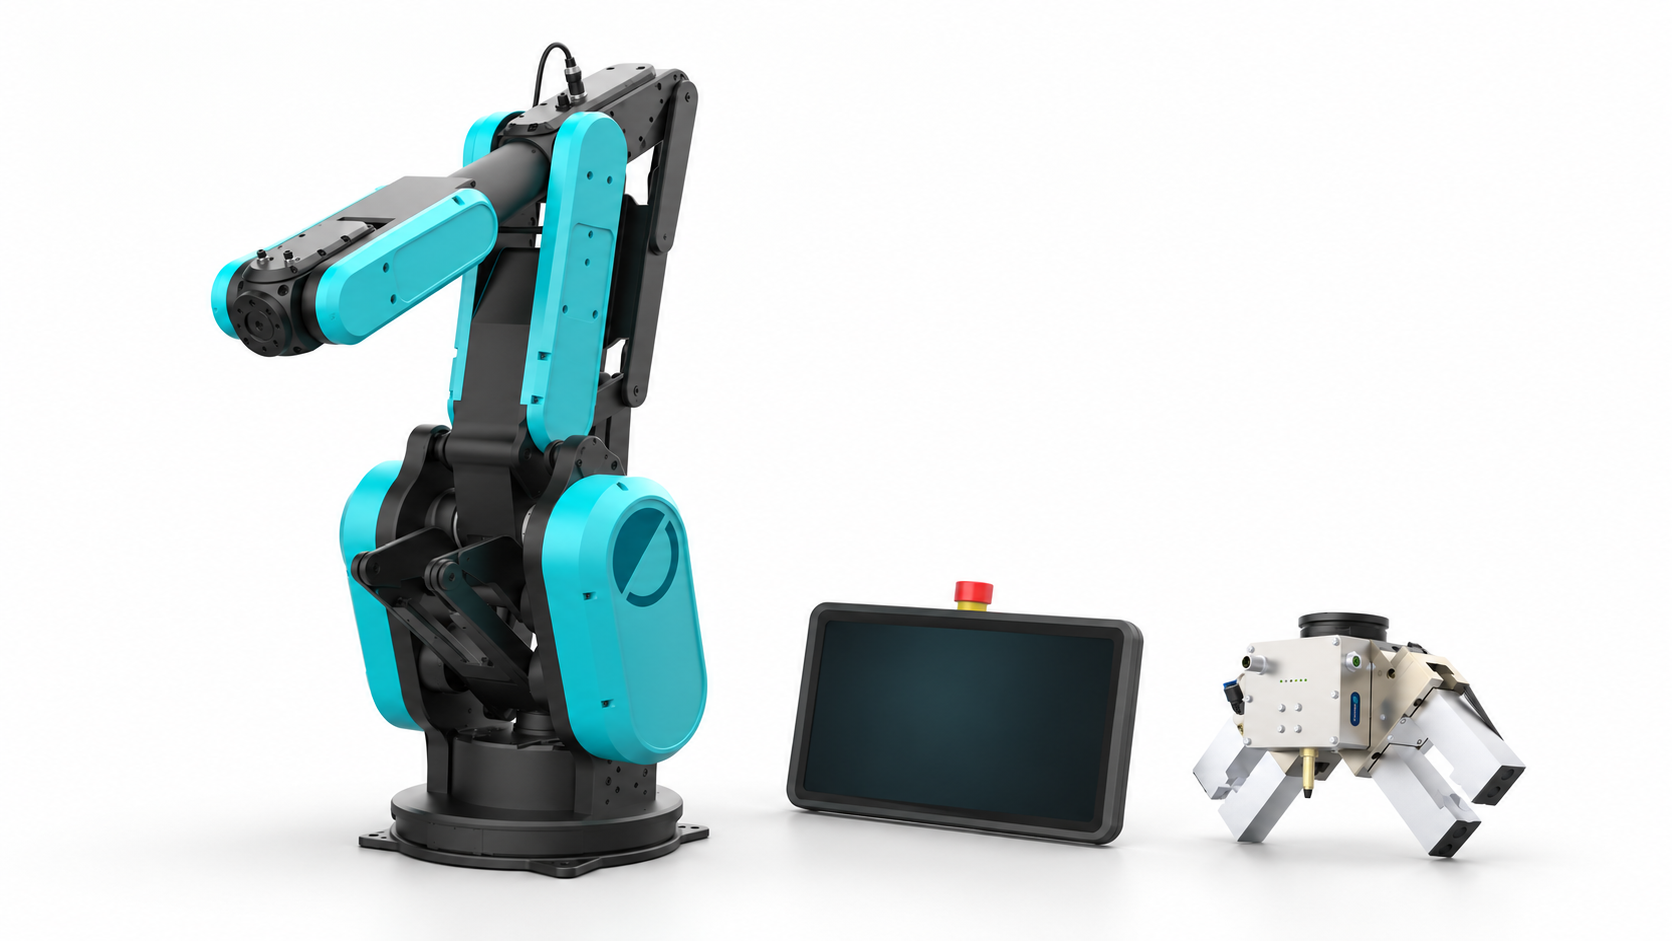
Robotics & hardware
Models and ROS 2
Choose the exact model and asset boundary; display read state or use separate local planning modes.
Explore roboticsSDKs · Middleware · Simulation · Data
Connect your application to robot models, visualization, simulation, recordings and industrial systems. Choose your task and follow a guide with clear inputs and results.
See how these tools fit into the software stack in the PLEXA OS architecture · Coming soon.
Choose the exact model and asset boundary; display read state or use separate local planning modes.
Explore robotics
Choose a browser view, editable cell or simulator; look up research benchmarks separately.
Choose a tool
Identify the source and time basis, verify MCAP and inspect stored data in diagnostic tools.
Open the data path
Connect orders, process history, telemetry and local workflows through explicitly bounded adapters.
Explore systems19 / 19 tools · Each guide owns its versions, sources and remaining boundaries.
 Robotics & hardware

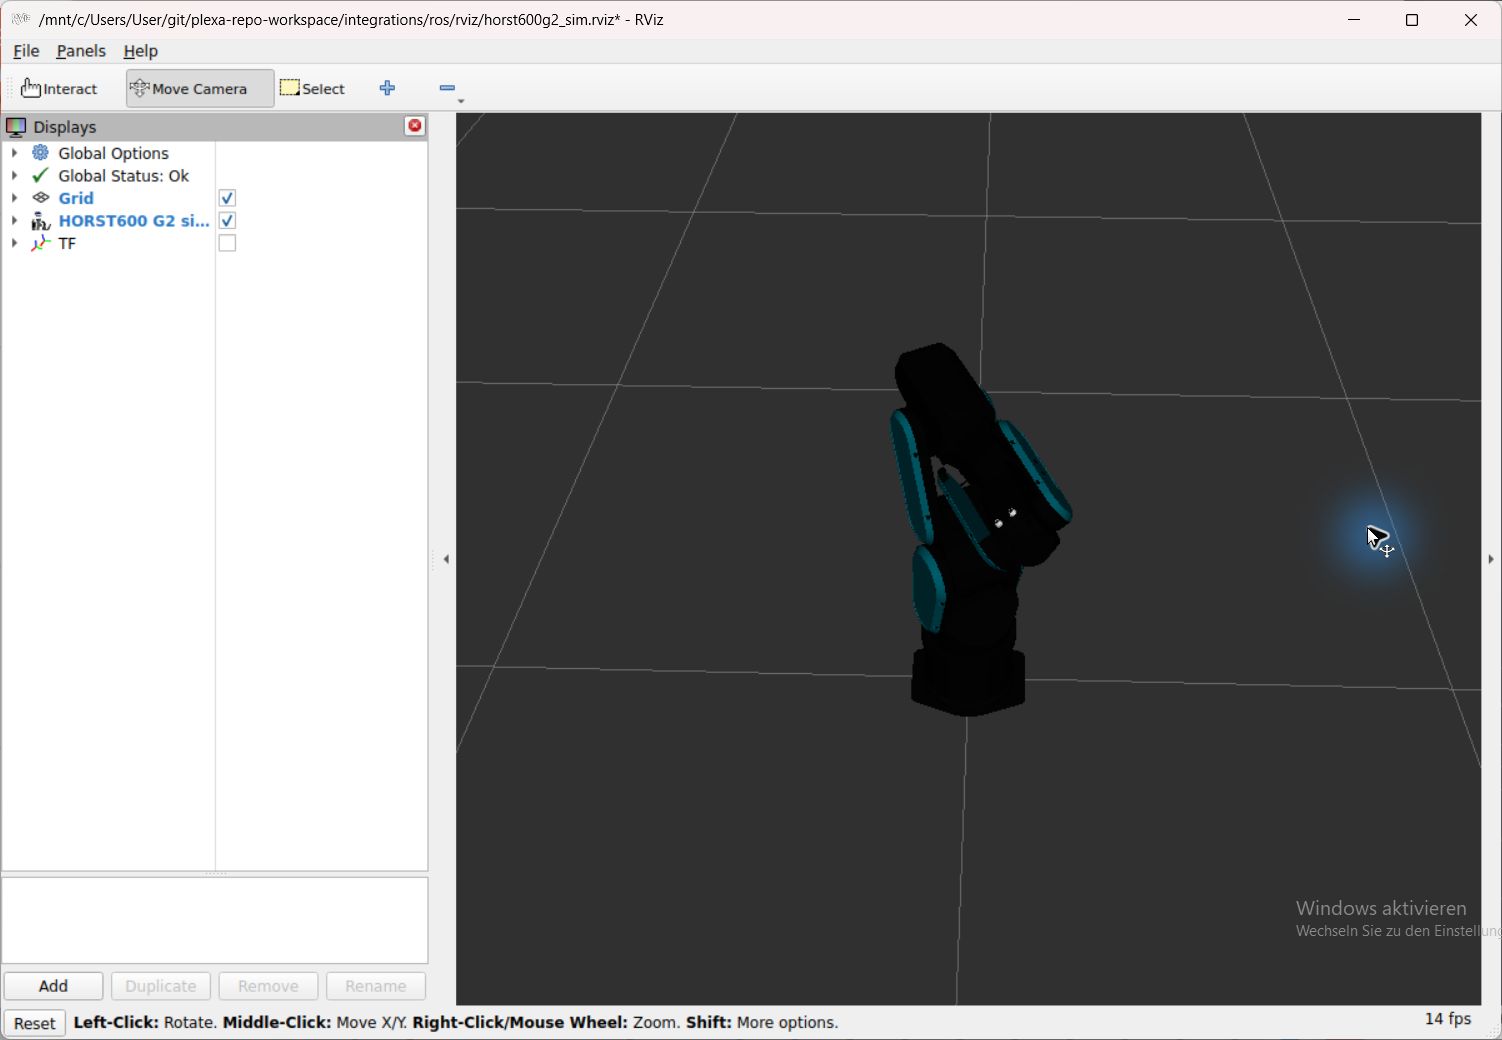
Middleware · Offline preparation
Display simulator joints and frames in RViz, or prepare a local G2 planning and Gazebo view.
 Simulation & visualization

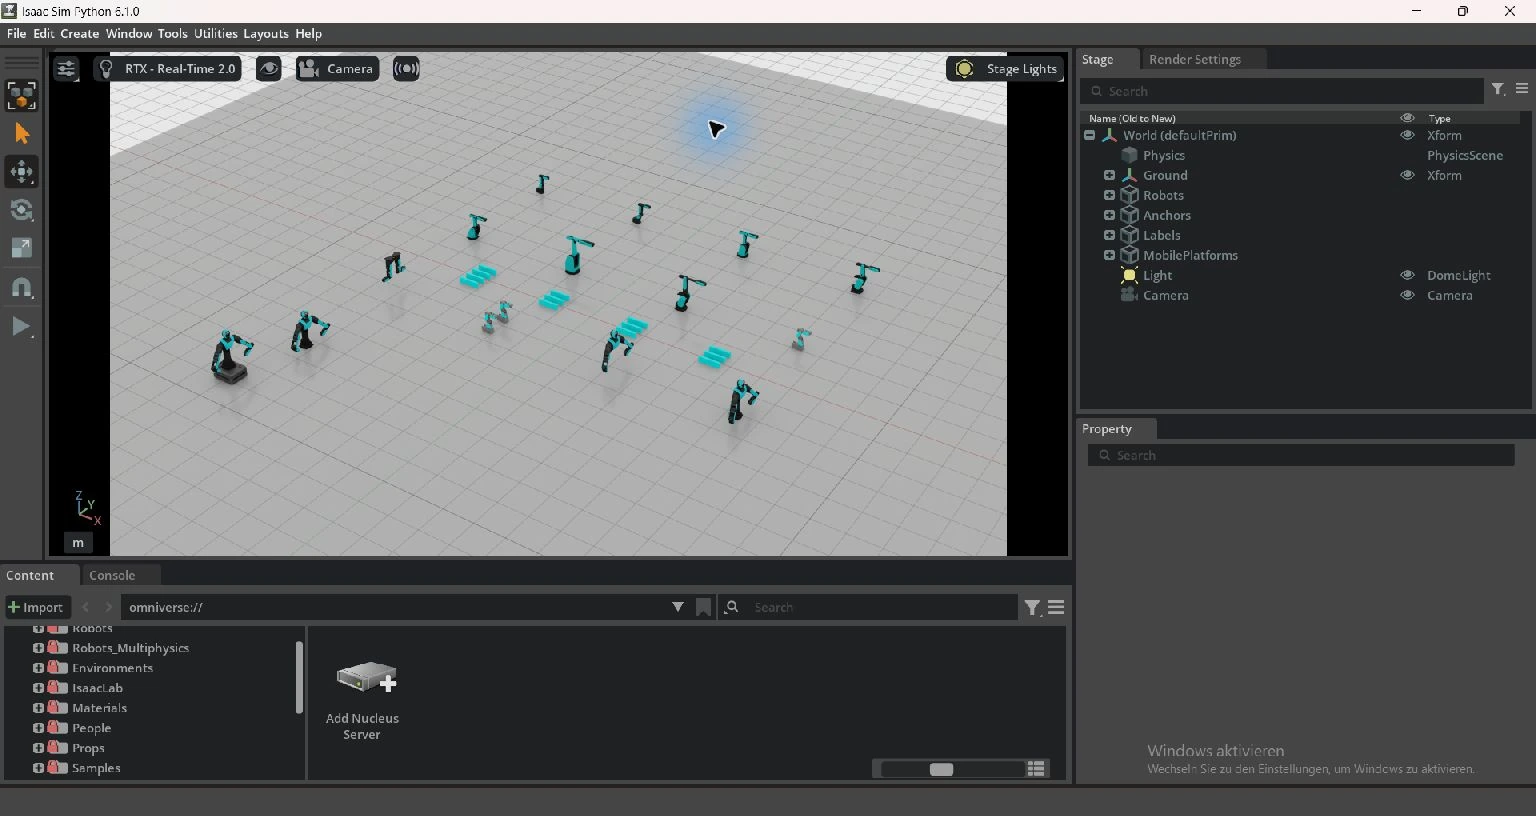
Simulation · Experimental
Open shared USD assets, compare models in a robot portfolio and inspect local scenes.
Simulation & visualization
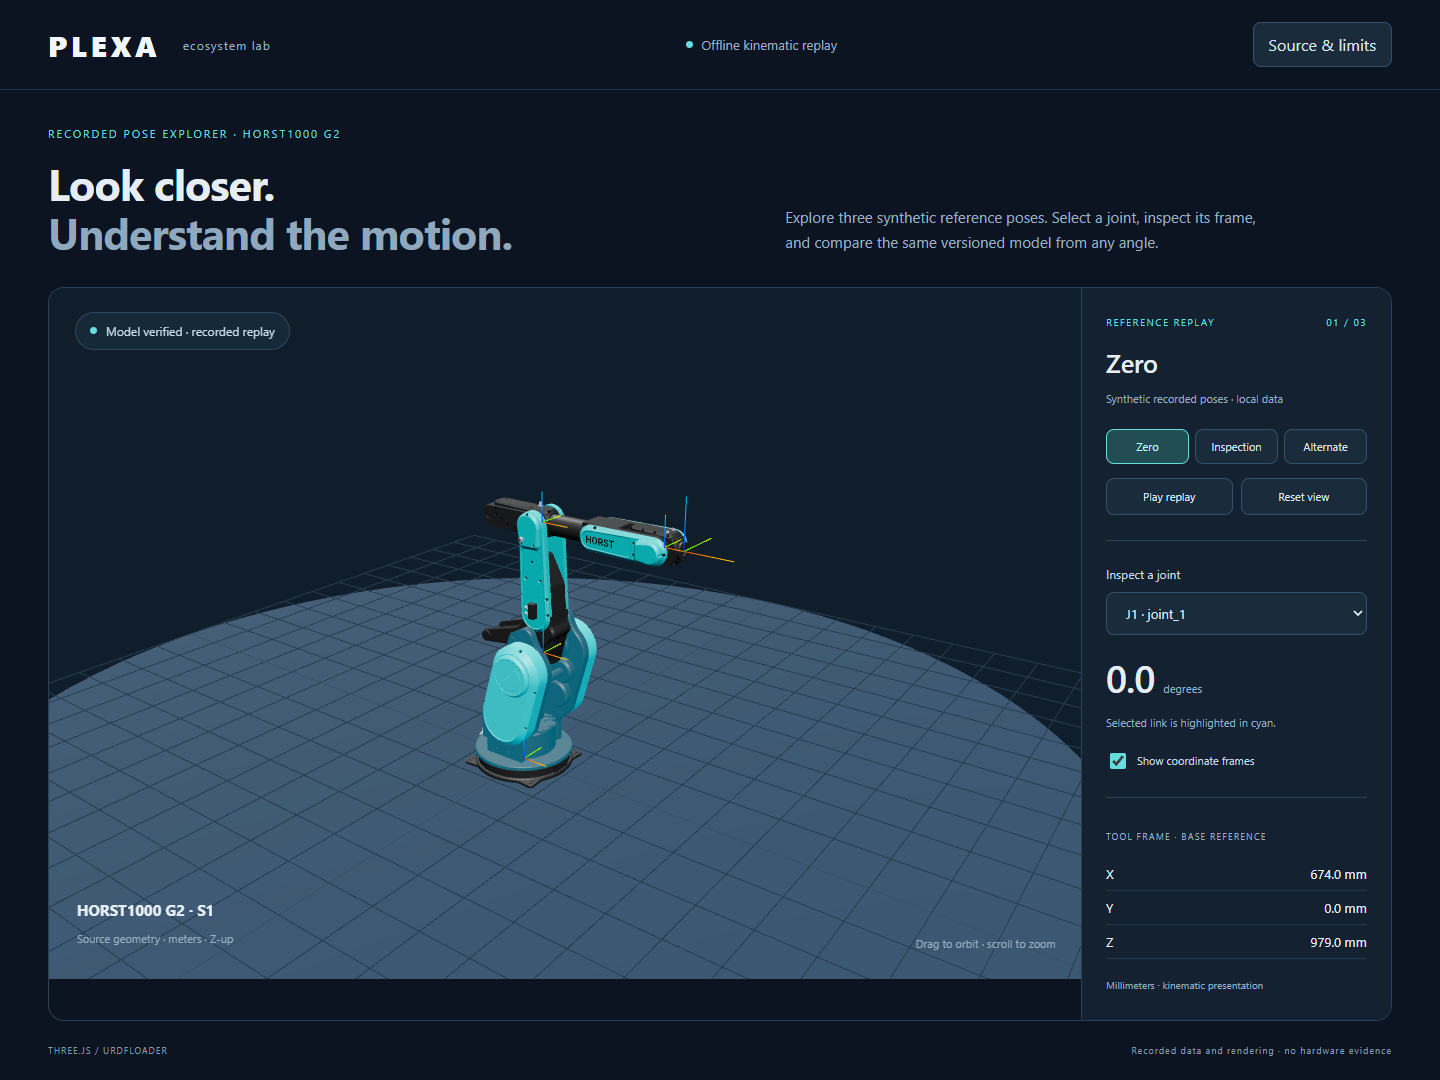
Browser · Recorded poses
Compare G2 poses in the browser, select joints and read tool frames on desktop and mobile.
Simulation & visualization
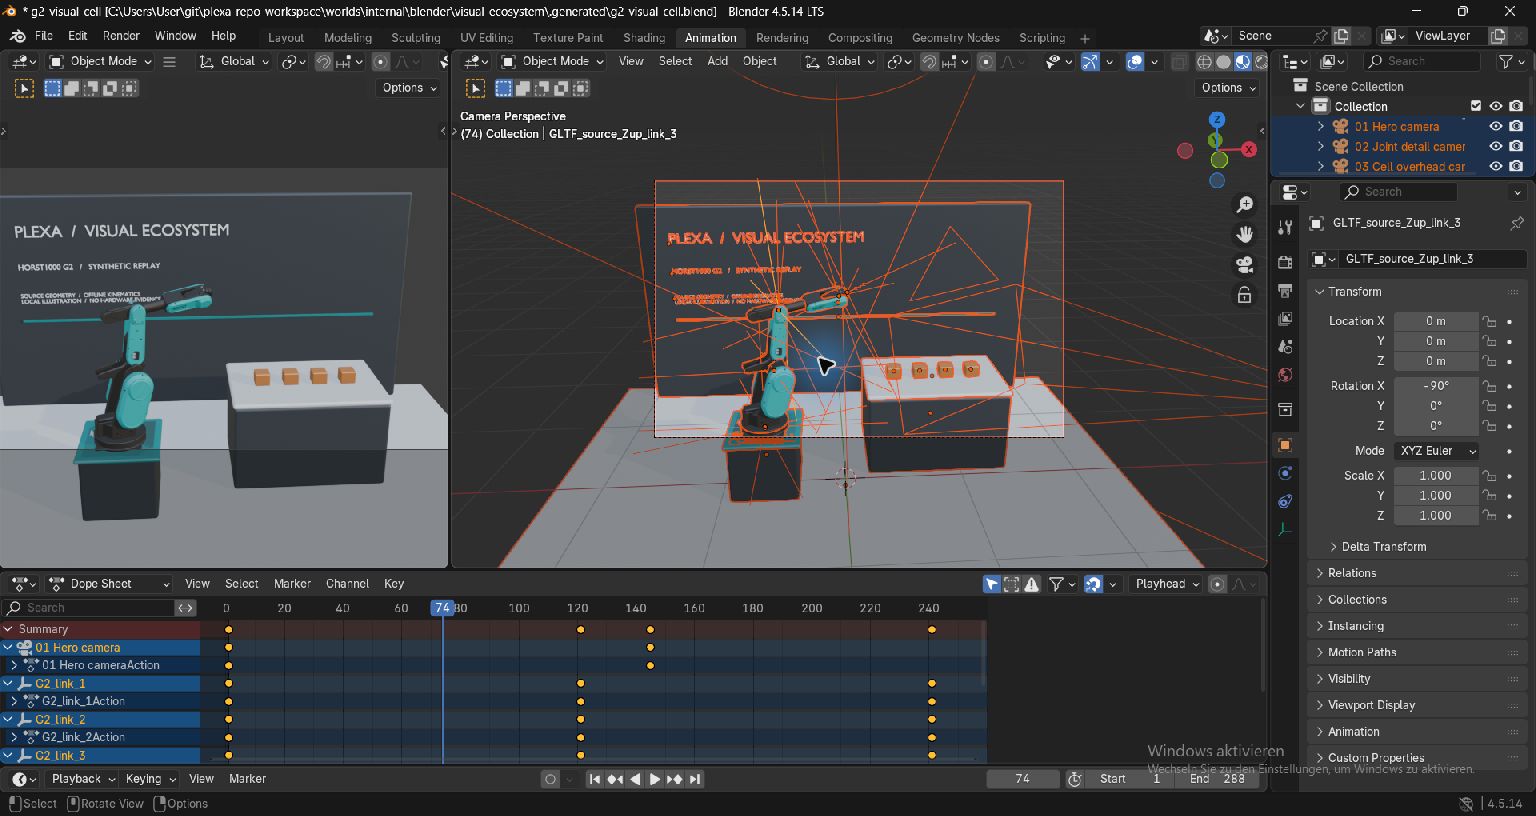
Blender · Offline cell
Build an editable G2 cell and inspect joint and camera keyframes in the native timeline.
Simulation & visualizationWebots · Native checks
Prepare a source-bound G2 cell for local kinematic preview with meshes and frames.
Simulation & visualizationUnreal · Editor gate
Compose a USD scene from shared assets. Native Editor use requires the launcher and an eligible license.
Simulation & visualizationRoboDK · License gate
Prepare G2 geometry and kinematics in a local station. Saving and reopening require the appropriate license.
Simulation & visualizationCoppeliaSim · License gate
Prepare an adapter from shared model data. Native execution requires an activated eligible commercial license.
 Data & diagnostics
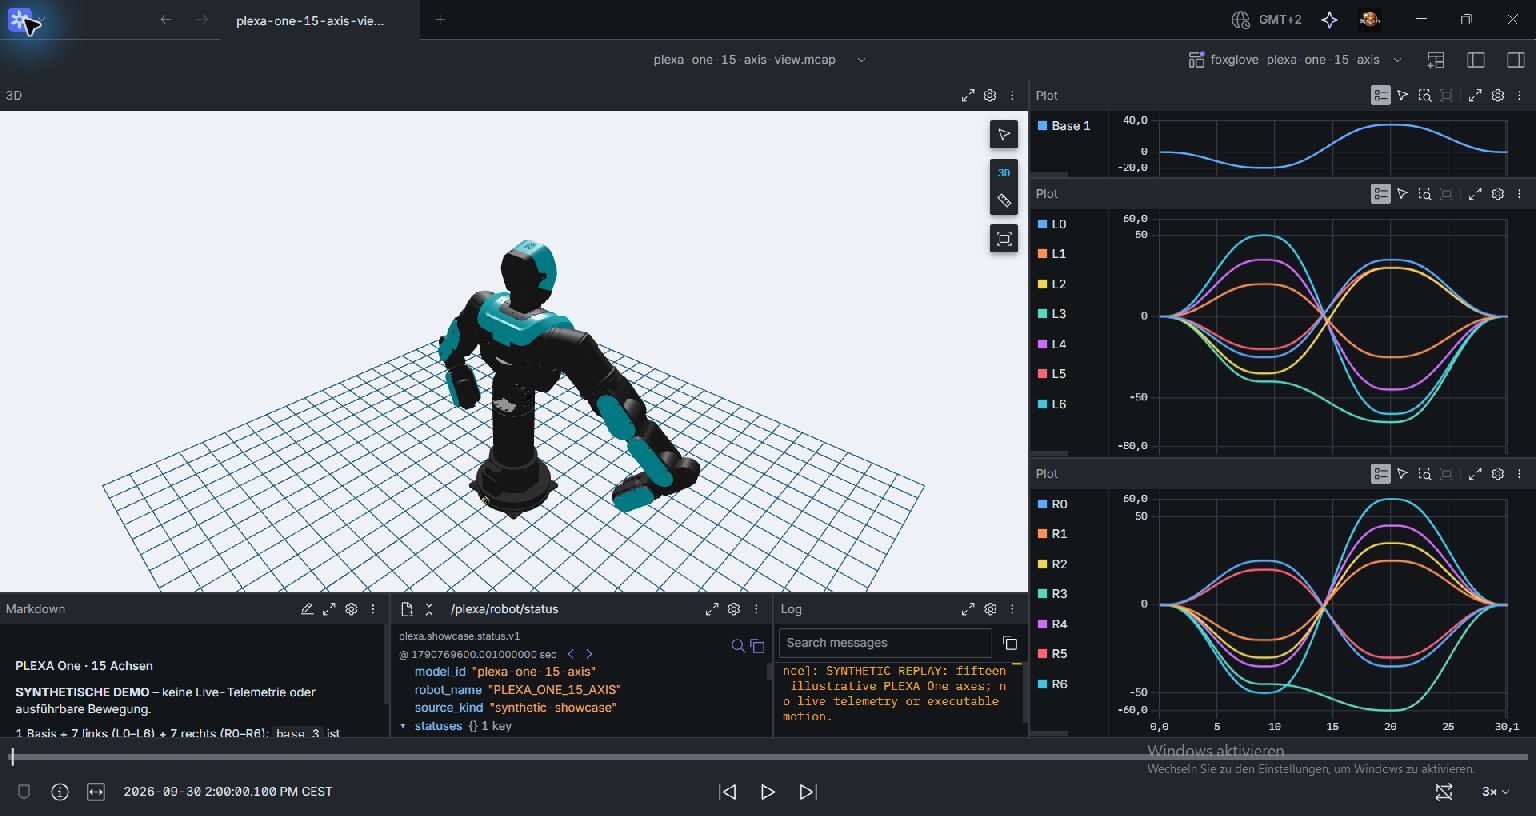
Data · Experimental
Read HORST and PLEXA telemetry, record MCAP and inspect signals with Foxglove, Parquet and DuckDB.
Data & diagnostics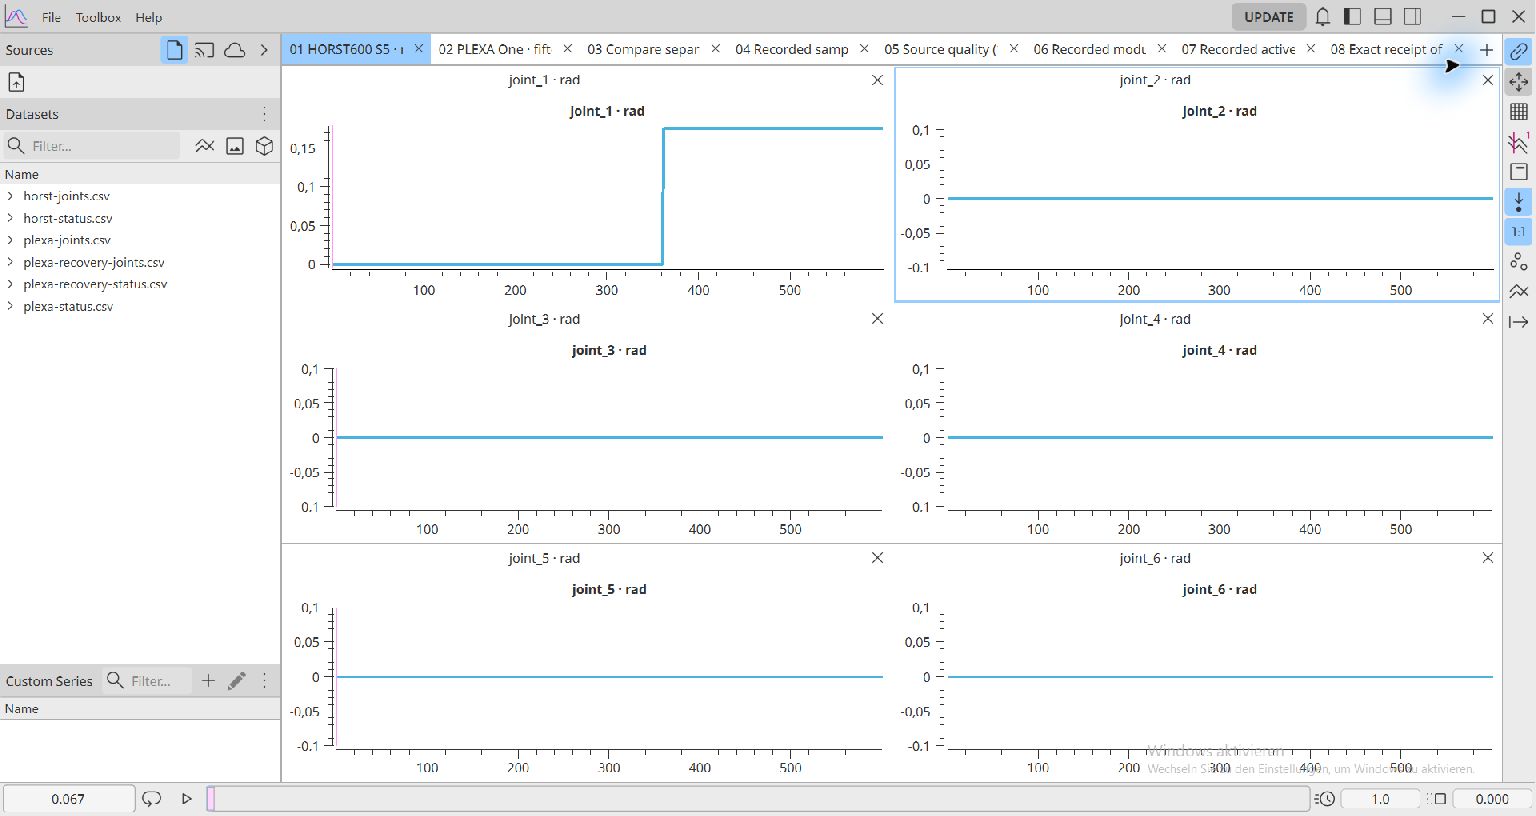
PlotJuggler · Saved signals
Export saved S5 and PLEXA signals to CSV and compare joints, time gaps, source quality and module ages.
Systems & processes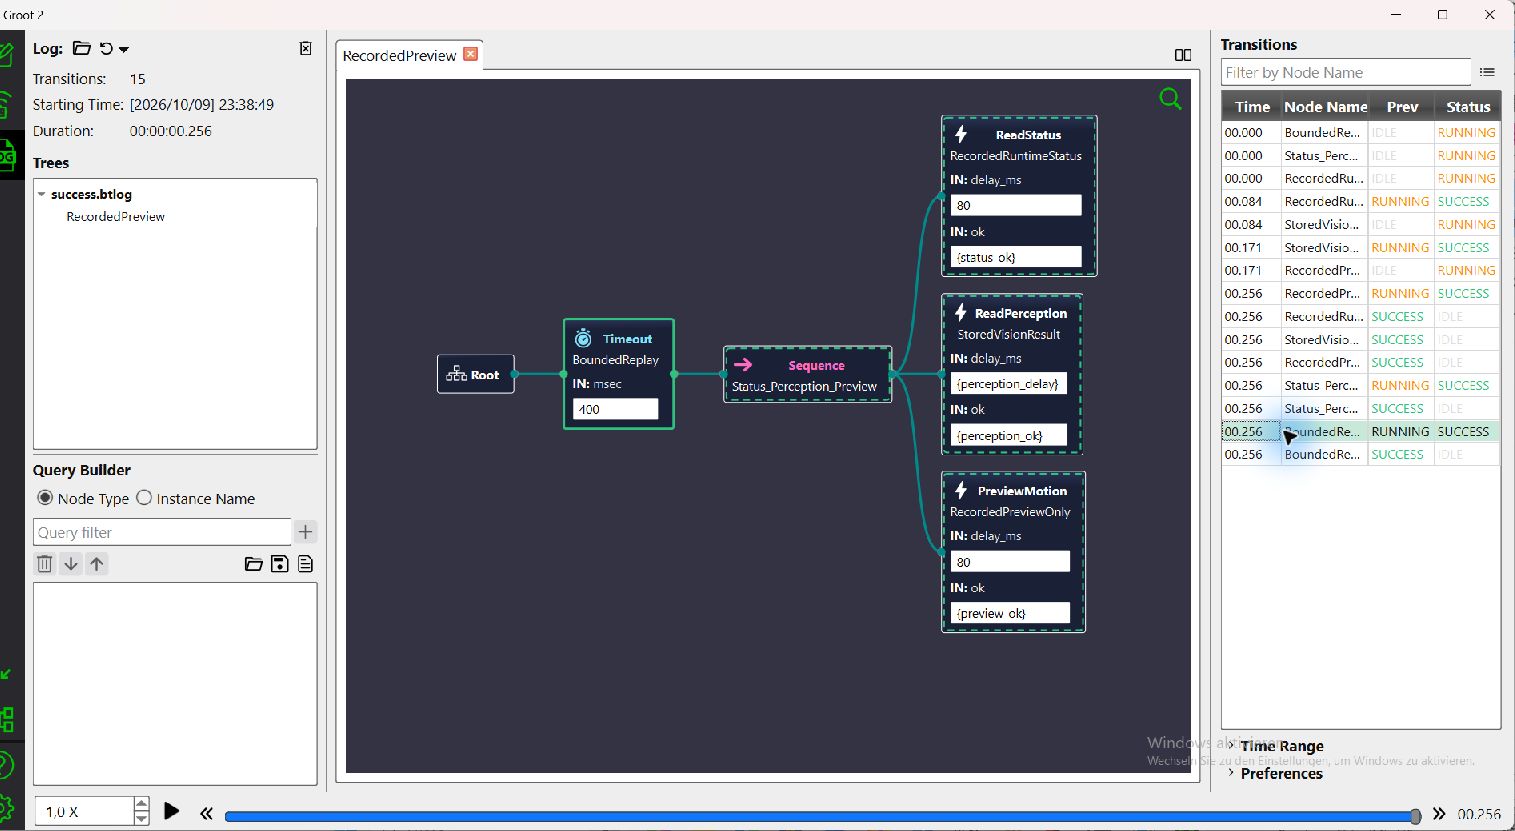
BehaviorTree · Recorded orchestration
Replay status, stored perception and planning preview as a tree. Compare success, failure, timeout and cancellation in Groot2.
Systems & processes

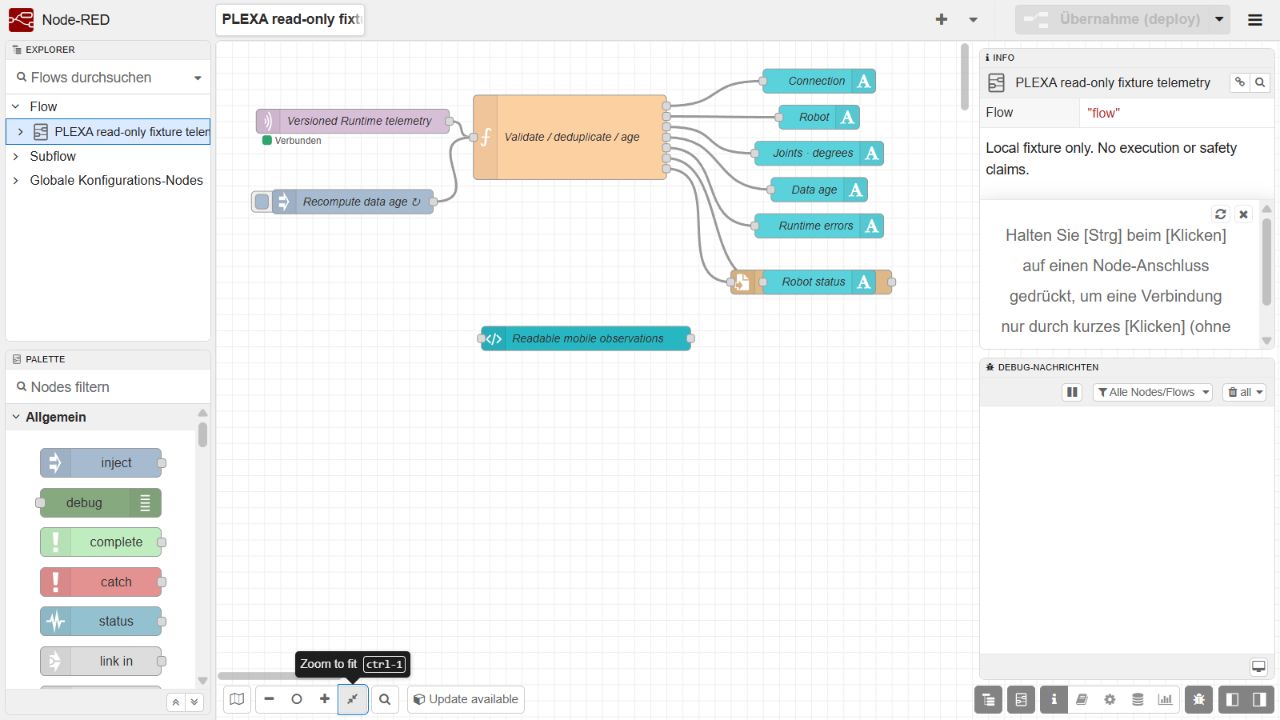
Industrial · Telemetry & commands
Browse Robotics types, display telemetry quality and age, or explicitly set up the separate command path.
Systems & processes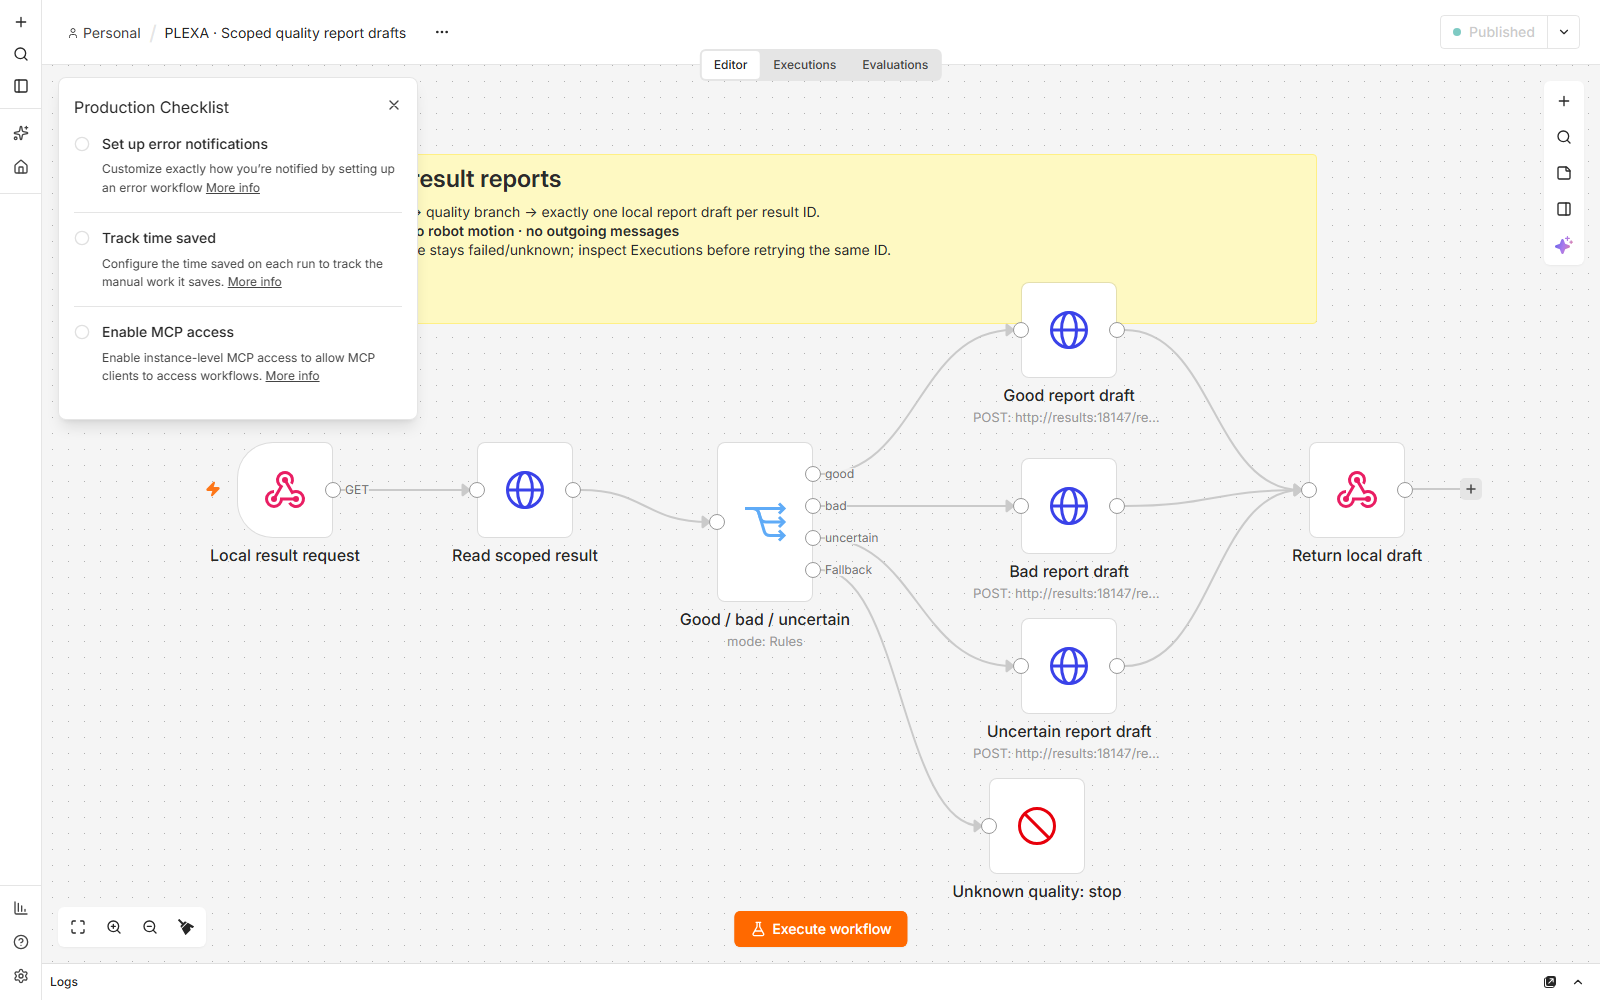
n8n · Local reports
Branch synthetic quality results on good, bad or uncertain and maintain one local report draft per result identity.
Systems & processes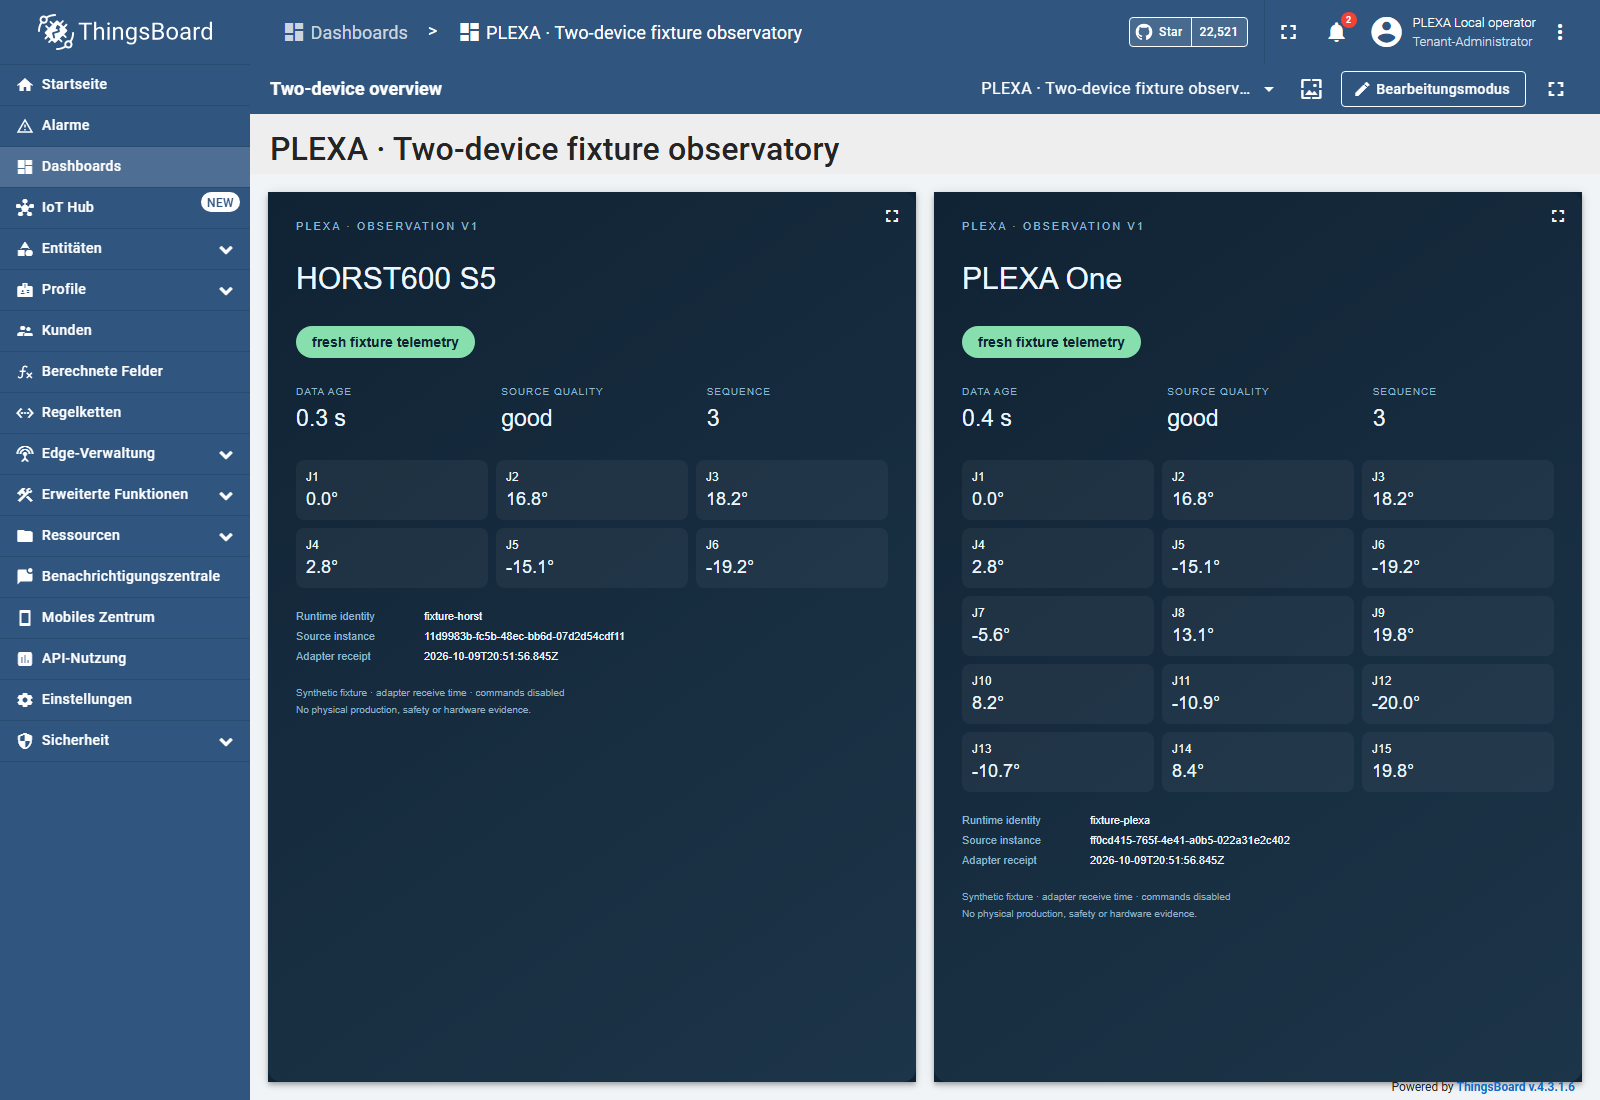
ThingsBoard · Two devices
Display S5 and PLEXA as distinct devices and follow axis values, source quality, data age and recovery.
 Simulation & visualization
Research · bounded native checks
Compare MuJoCo, Genesis, Newton/Warp, Playground, ManiSkill and cuRobo for source-bound local research workflows.
Data & diagnosticsNative episodes · offline learning
Export native simulator episodes to HDF5, read them with SequenceDataset and compare offline predictions.
Data & diagnosticsZenoh · local synthetic fixture
Start two local peers, query last state and inspect freshness and new startup instances using synthetic S5 data.
 Systems & processes
Odoo · Orders and results
Map an order to a registered robot recipe and return its result as a traceable journal entry.
 Systems & processes
Grafana · Process history
Bring stored order results and telemetry together in a diagnostic view.