Component Kit Schunk EGP 40-N-N-B
General Guidelines
Note
This document serves as a helpful guide for assembling the Component Kits. It is not a step-by-step installation manual in the traditional sense.
Safety notice
Seek professional assistance if necessary to avoid dangerous situations and injuries.
Power supply
Before starting the assembly steps, make sure to power off the product. Once all assembly steps are completed, you can safely turn the power back on.
Assembly Parts
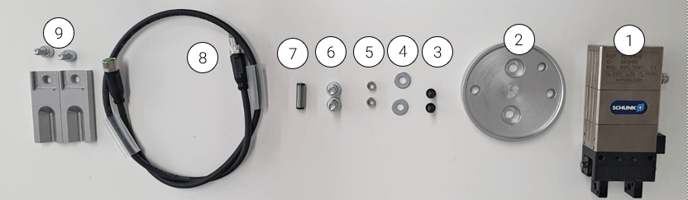
| Nr | Quantity | Description |
|---|---|---|
| 1 | 1 | Electric Parallel Gripper EGP40-NNB |
| 2 | 1 | Adapter plate for Schunk EGP 40 NNB |
| 3 | 2 | Cylinder screw DIN 7984, M4x12 (low head) |
| 4 | 2 | Washers DIN 9021 measuring 4.3x12x1.00 mm. |
| 5 | 2 | Centering sleeve 6x5.3 mm for connecting the gripper to the adapter |
| 6 | 2 | Cylinder screw DIN 6912, M6x12 |
| 7 | 1 | Centering pin 6x14 M6 |
| 8 | 2 | M8 PUR Cable - 0.5 meters in length from Murr Elektronik |
| 9 | 2 | Cylinder screw for jaws M5x10 |
Required Tools
- Hex keys in sizes 2.5 mm, 4 mm, and 5 mm are required for the assembly process.
Procedure
Inserting the centering sleeves and mounting the adapter plate on the gripper
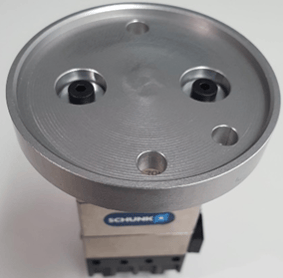
To ensure the centered assembly of the adapter plate on the Schunk EGP 40 NNB gripper, start by inserting the centering sleeves (6x5.3mm) into the holes of the gripper housing.
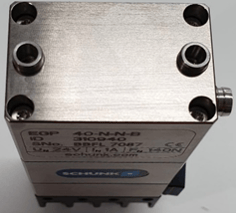
Next, press the adapter plate onto the centering sleeves. Note: due to the anodized coating on the adapter plate, it may not be possible to press it all the way to the gripper housing by hand. Once the adapter plate is firmly pressed by hand, secure it in place by attaching and tightening the washers (DIN 9021 4.3x12x1.00) with the corresponding screws (DIN 7984, M4x12).
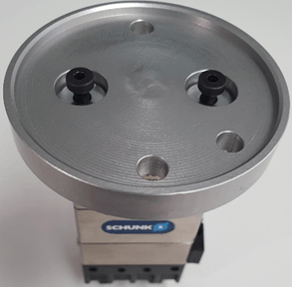
Note: After tightening, make sure that the adapter plate sits completely on the gripper housing. Clean the interface if necessary. Also, ensure that the screw heads do not protrude from the milling.
Make sure to use the correct screws (low head cylinder screw DIN 7984, M4x12) when attaching the adapter plate.
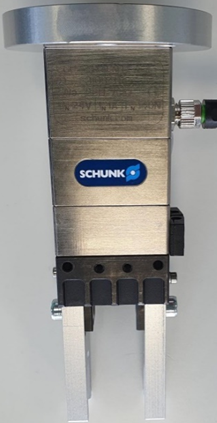
Attaching Gripper Jaws to Gripper Fingers
Next, the gripper jaws are mounted on the base unit. To do this, each jaw is pressed onto the screwing possibility of the gripper finger from the outside and secured with the help of the M5x10 screw.
Montage Greifer an Roboterflansch (Tragarm 3)
In the next step, align and secure the pre-assembled gripper to the robot flange. Start by inserting the centering pin (6x14 M6) into the hole on the robot flange.
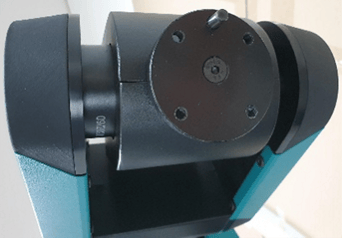
Next, align the pre-assembled gripper with the help of the centering pin and press it onto the robot flange in the correct orientation. It is important to ensure that the surfaces are clean and free from any contaminants before attaching the gripper to the robot using the cylinder screws DIN 6912, M6x12.
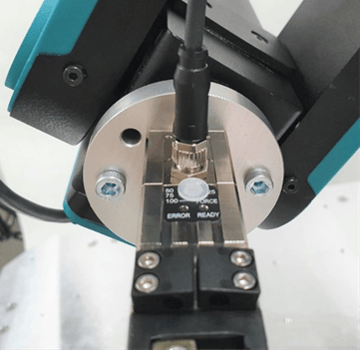
Electrical Final Assembly
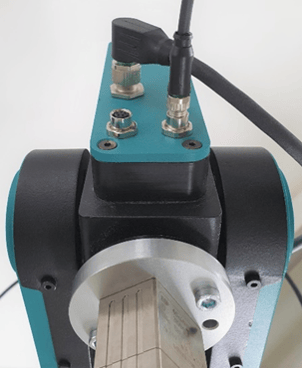
In the final assembly step, the electrical final assembly is carried out to ensure data transfer between the robot and gripper. Here, the supplied cable (M8 PUR cable) is first screwed onto the electrical interface of the gripper.
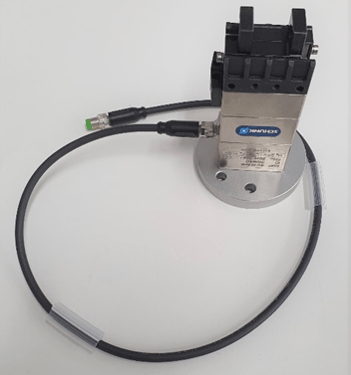
After that, the transmission cable is screwed onto the robot. For this purpose, the right socket on Robot Arm 3 is used. Once communication is ensured, the gripper can be controlled in horstOS via TOOL-OUTPUT-1 and TOOL-OUTPUT-2.