
PLEXA One HDK
Industrial Humanoid Development Kit
Your application.
Built on industrial robotics.
Bring your software. Combine PLEXA One, tools, perception and compute into a platform for your process.
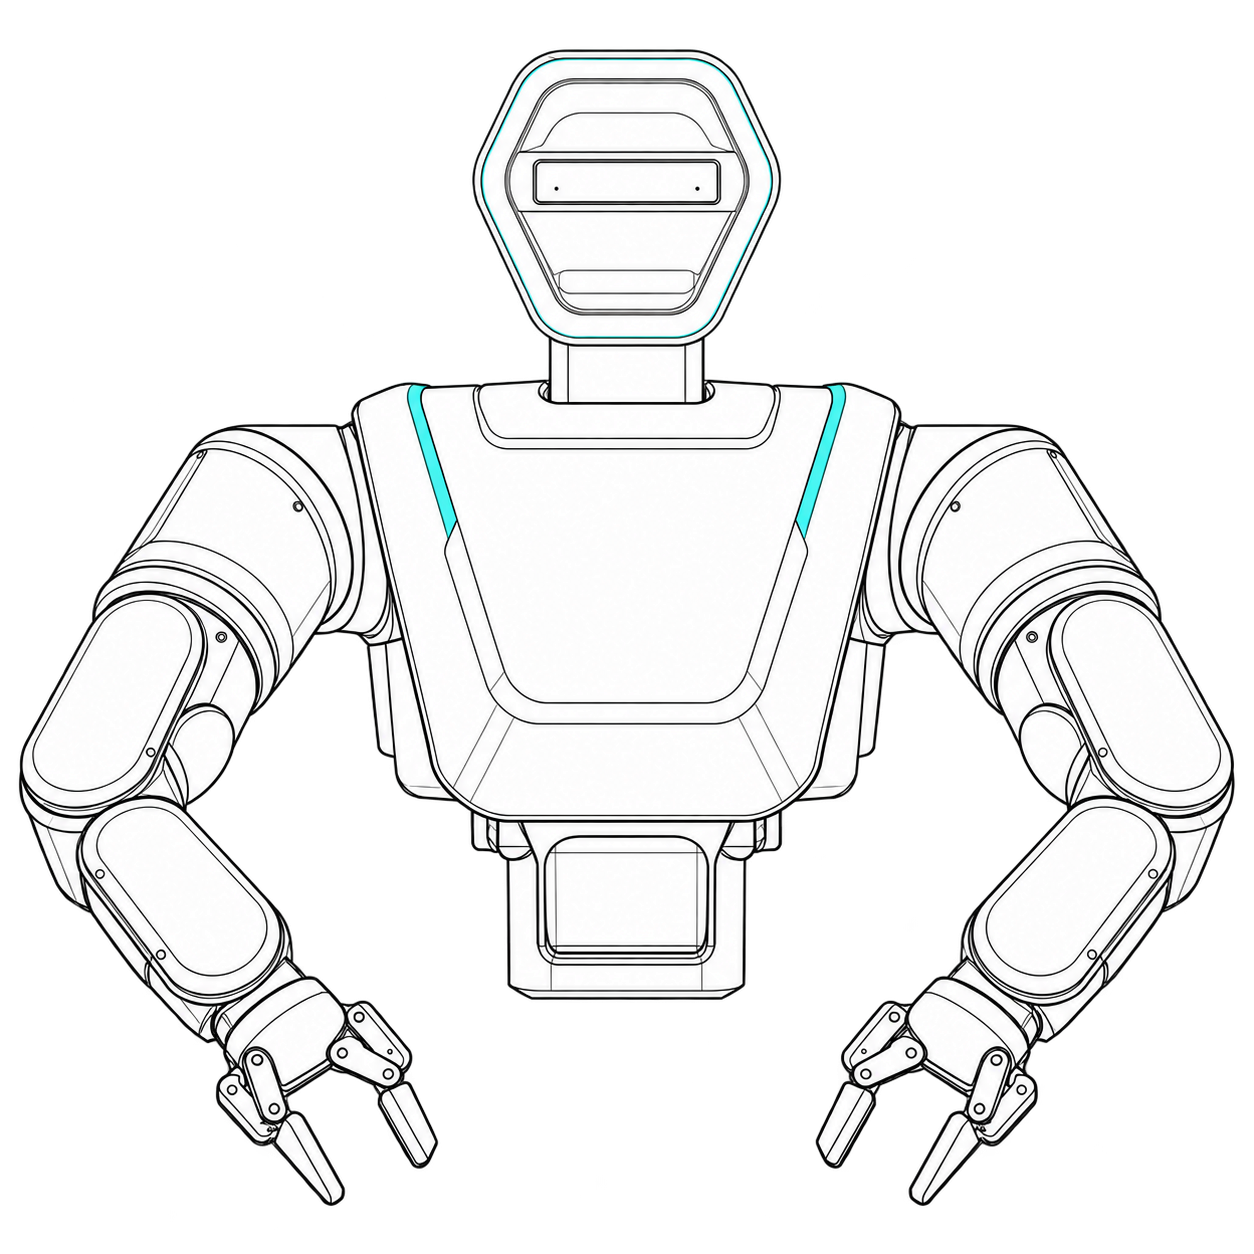
Humanoid Development Kit: industrial robotics for your perception, grasp planning and application logic.
Platform · Engineering chapters · Integration steps
An industrial foundation for your application
fruitcore combines industrial robot and Robotic Solutions experience with modular mechanics, tools, perception and safety.
The hardware documentation and Robotic Solutions manuals cover connections and service; the product website presents mechanical options.
Explore the complete platform
Compare stationary, linear-lift and swivel-lift variants. Explore components and original platform models in 3D.
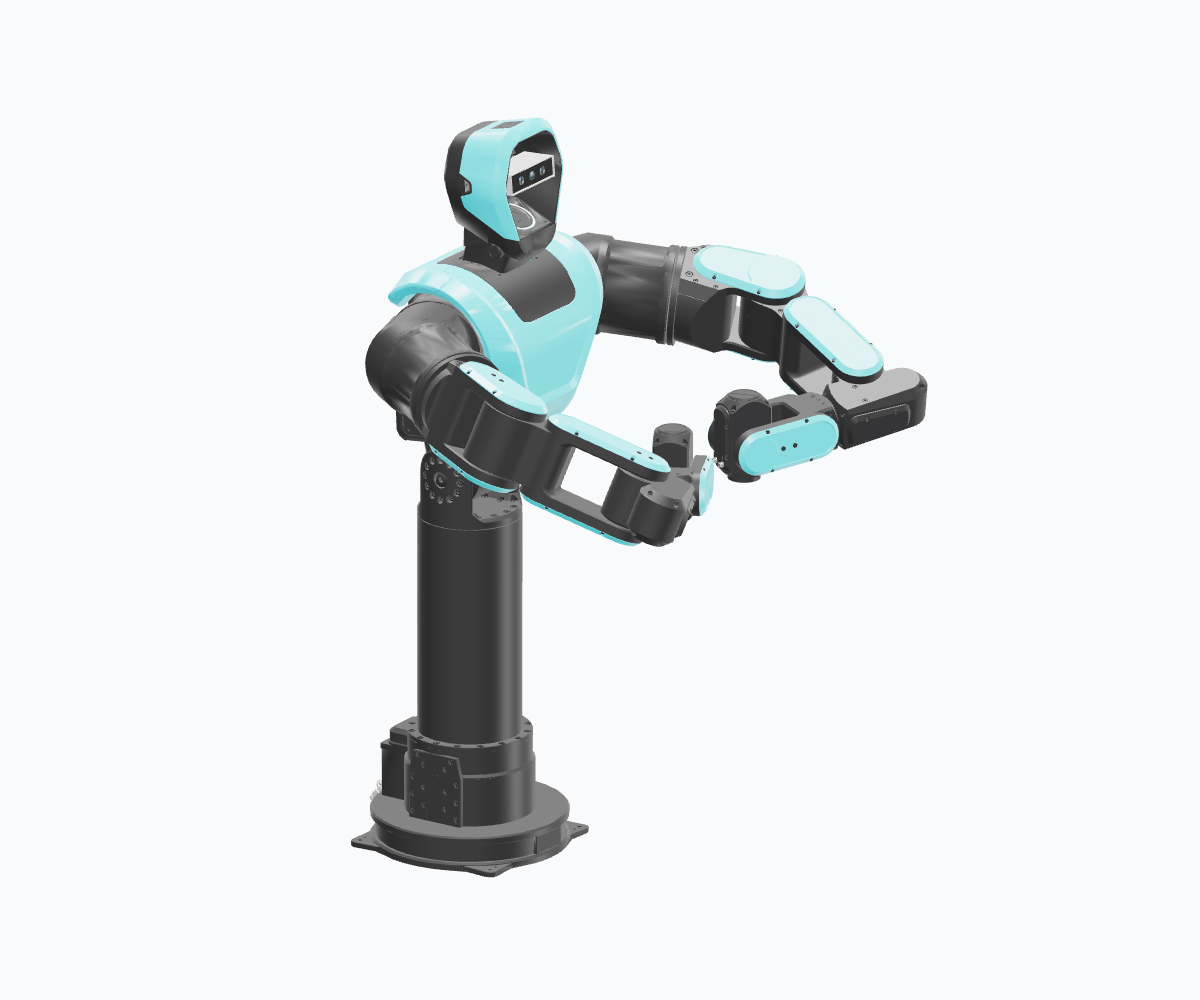
Workstations · machine tending
PLEXA One S1
A fixed working height with a rotating column. A starting point for manipulation at workstations and machines.
- Column module
- S3
- Robot axes
- 15
- Shown mounting
- OEM · NONE
PX1-H1-T1-S3-NONEOptional · loads the 3D model on request
Continue on the website: 3D applications · Working-envelope comparison · Hardware configurator.
Engineer the system, step by step
Start with the structure and connections, then add the tools, observations and software your process needs. Each chapter leads to the next engineering decision and the relevant detailed documentation.
Your application on a defined platform
| Responsibility | Scope |
|---|---|
| Platform and robot control | Selected mechanical configuration, documented control interfaces and agreed tool, sensor and host connections. |
| Integrator application | Perception, grasp planning, task logic, machine handshakes and orchestration in your software stack. |
| Complete installation | Mechanical and electrical integration, frames and calibration, coordinated safety functions, application checks and handover. |
Your software follows a common loop: observe → choose a grasp → request execution → assess the result. Continue with software integration, the local quickstart and the Robot APIs.
Example: bring your own application logic
An integrator combines part detection and grasp planning on a stationary PLEXA One with task-specific tools, cameras and an application host. Linear-lift or mobile-base variants extend the setup for the task.
From selection to operation
Select the platform
Compare structure and mounting, then record the mechanical SKU for your setup.
Configure the hardware · Start with the local quickstart · Discuss your application