
Bimanual handling
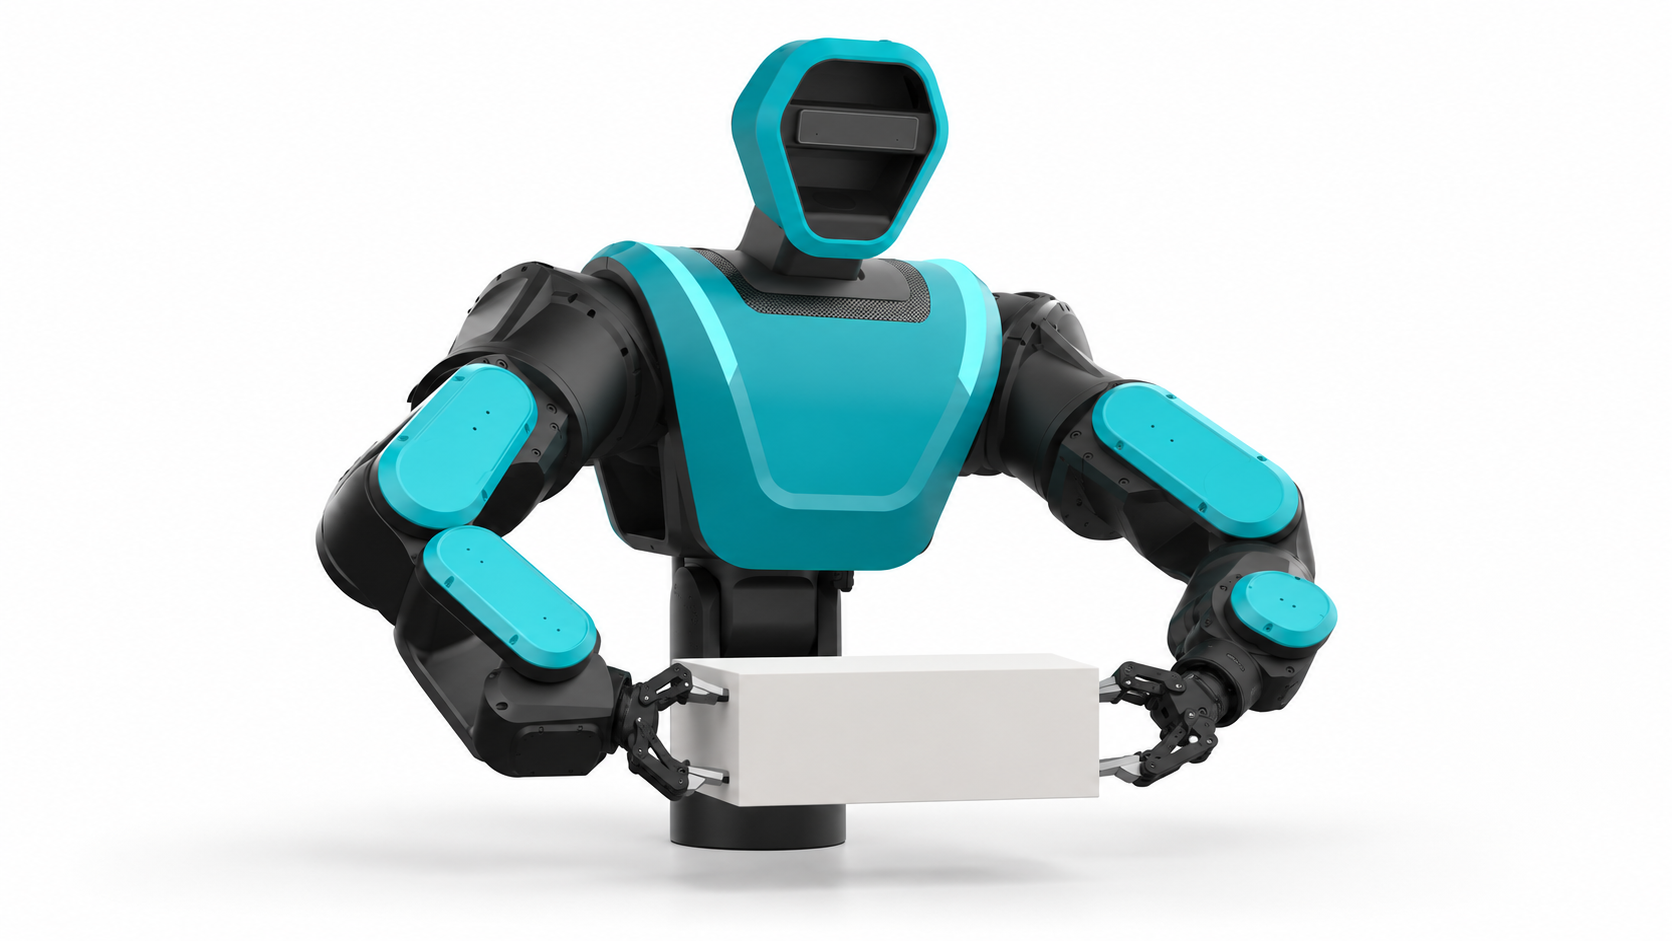
Explore how two arms share a workpiece, coordinate reference frames and organize a common task. The concept connects robot geometry, observation and coordinated requests.
Coming soon
A focused guide and practical examples for this concept are being prepared.