
Vision and touch
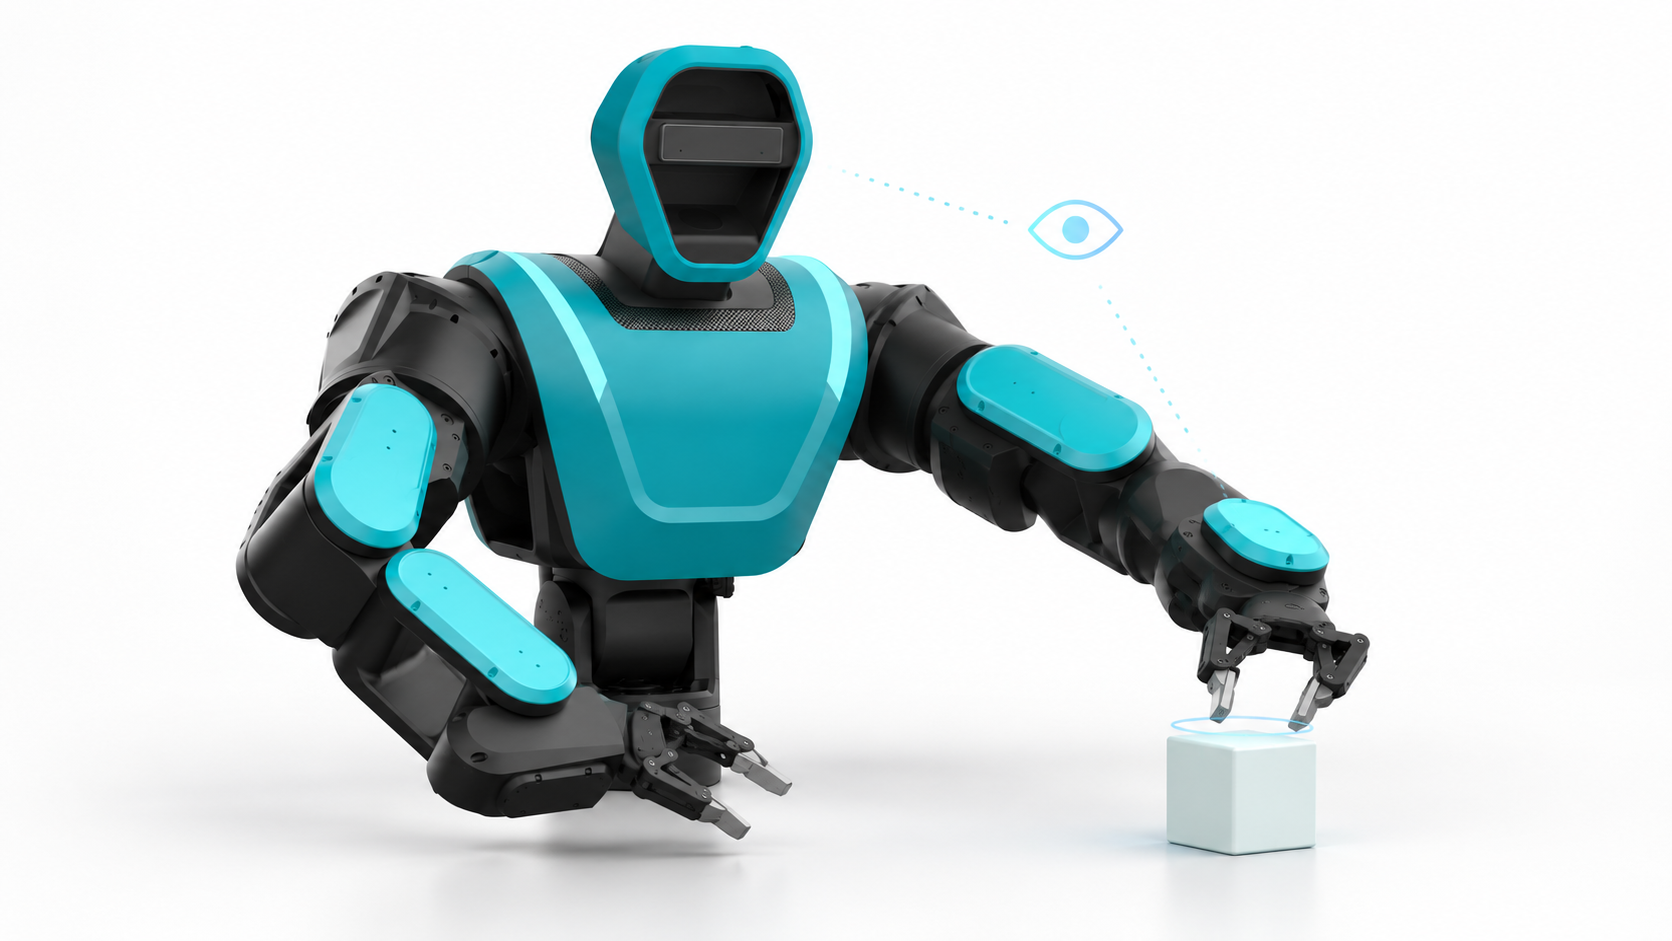
Combine visual and contact observations with the state of a robot application. The concept shows how perception can inform a next step while keeping observations and actions distinct.
Coming soon
A focused guide and practical examples for this concept are being prepared.