
Robot kinematics
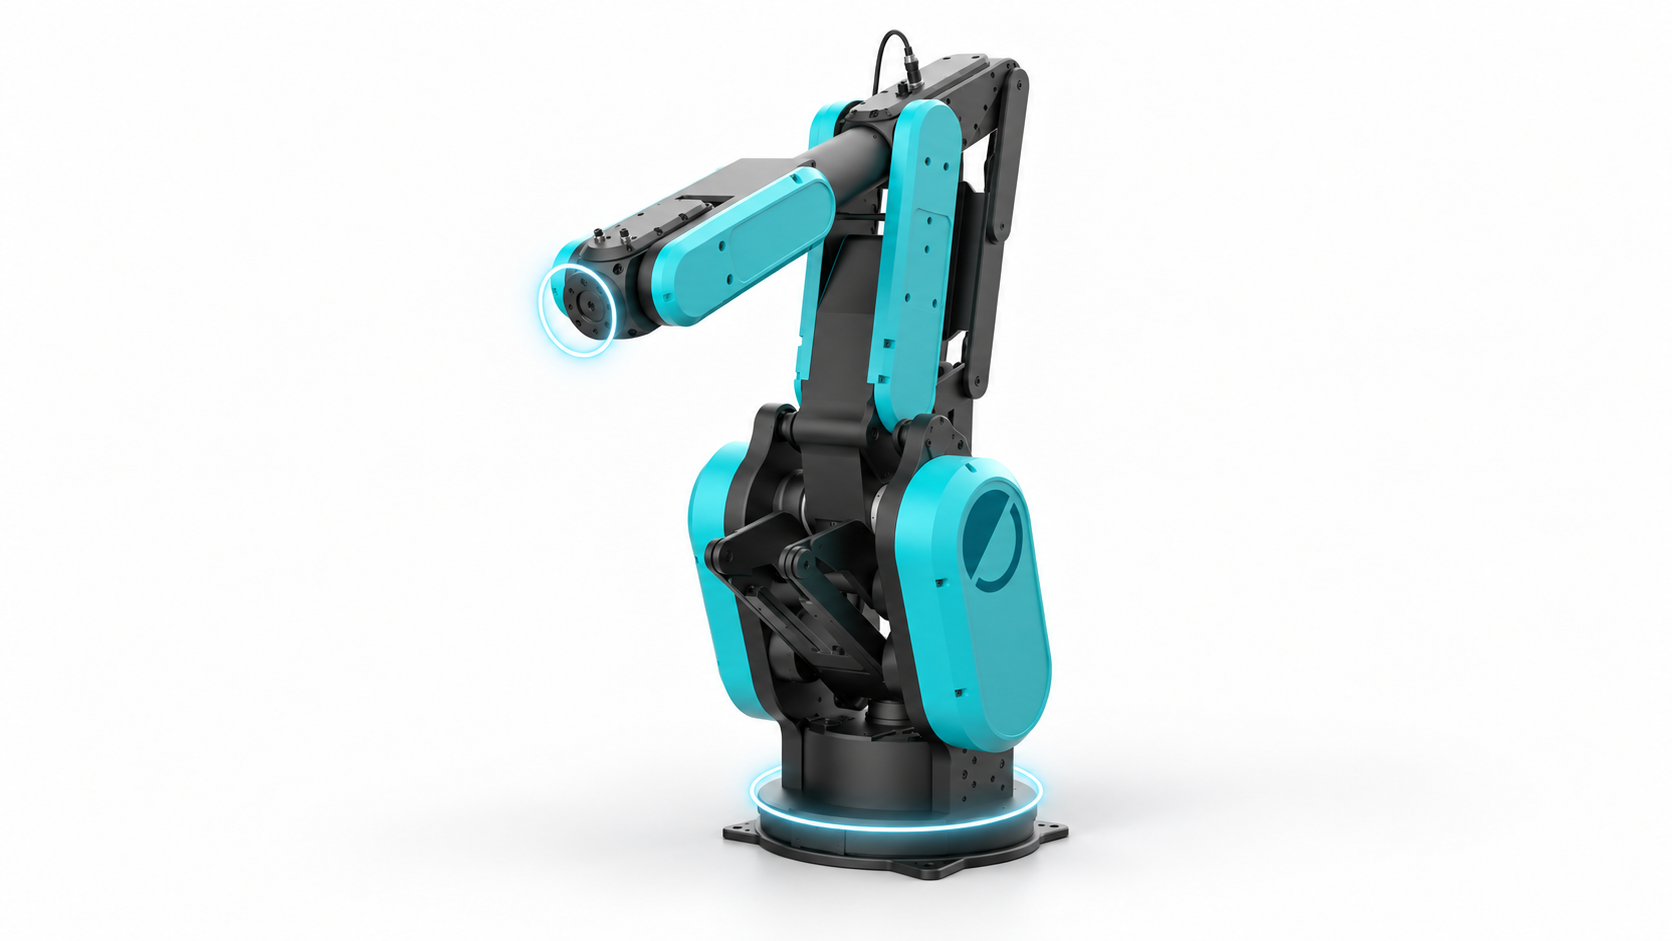
Relate joint positions, tool pose and coordinate frames. A consistent robot model helps your application describe targets and understand a motion preview.
Coming soon
A focused guide and practical examples for this concept are being prepared.