
Teleoperation
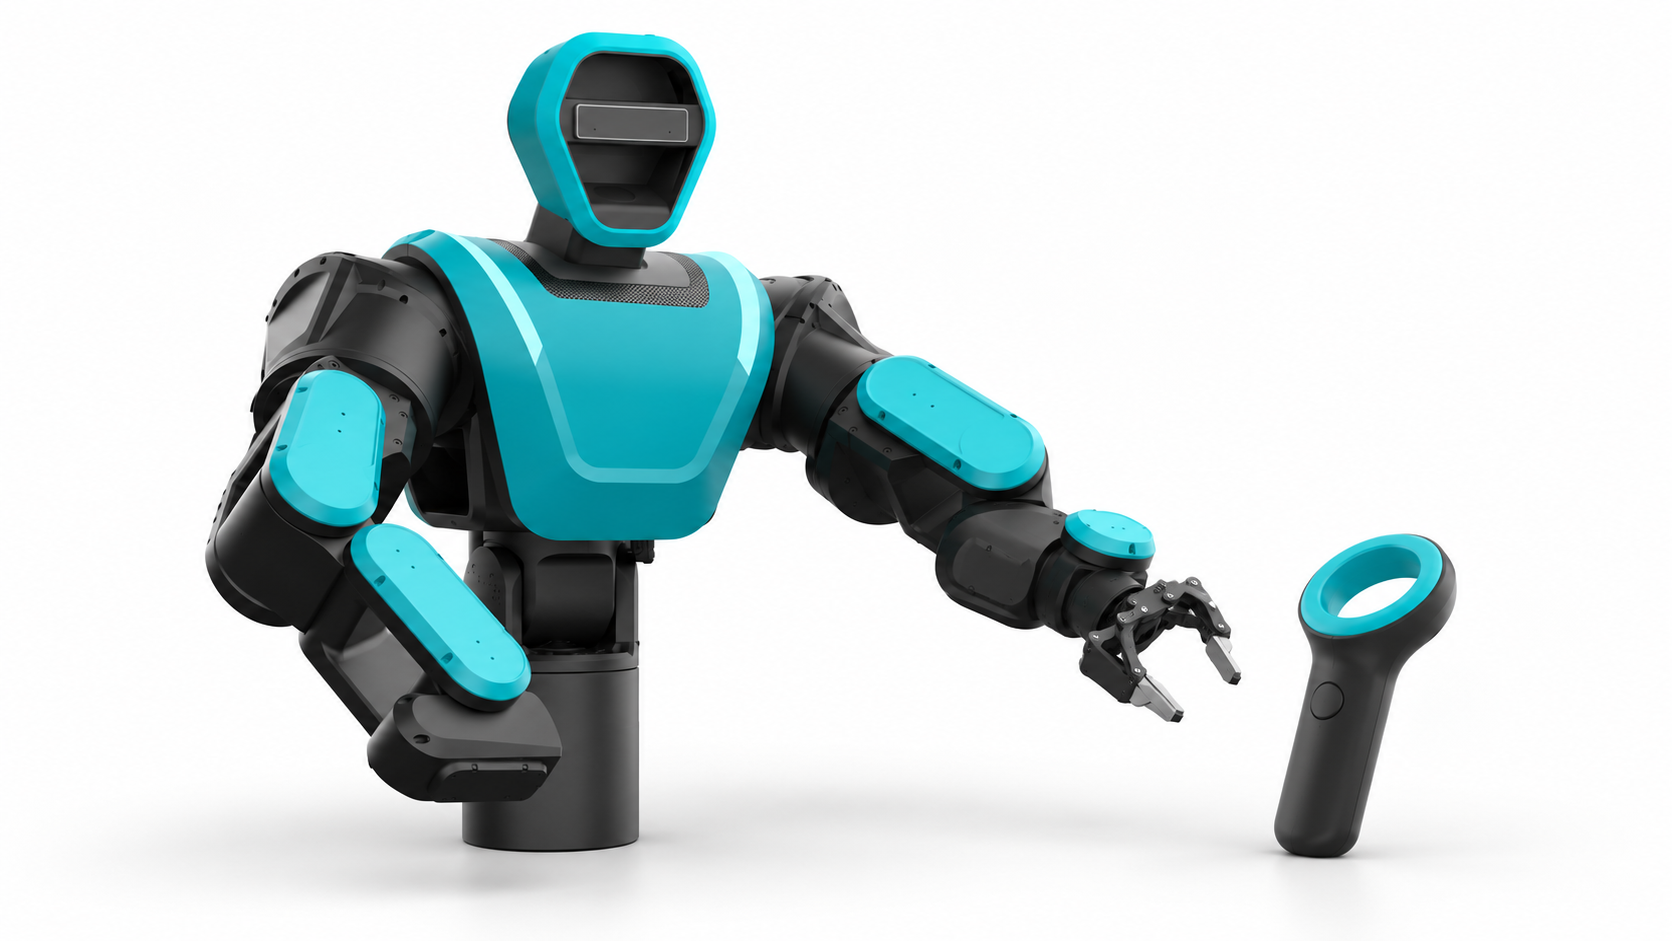
Translate human input into an explicit robot command workflow. Teleoperation connects an input device, a selected robot and observable execution, and can support demonstration collection.
Coming soon
A focused guide and practical examples for this concept are being prepared.